2026
Elected member, Sigma Xi
The Scientific Research Honor Society, elected by the Princeton mathematics department upon graduation
I am a first-year M.S. student in Computer Science and Engineering at the University of Michigan. I received my B.A. in Mathematics from Princeton University, where I was fortunate to work with Prof. Jia Deng, Prof. Zhuang Liu, Prof. Marc Aurèle Gilles, and Prof. Boris Hanin. I was also fortunate to learn from Prof. Charles Fefferman and Prof. Amit Singer, who greatly changed how I understand mathematics and intellectual life.
My research spans embodied intelligence and multimodal learning. I have worked on robotic manipulation, tactile sensing, and sim-to-real transfer (including physical simulation and synthetic data generation), as well as reasoning evaluation in vision–language models. I have also explored theoretical machine learning: critical batch size and scaling laws, statistical inference, and spectral methods for high-dimensional learning.
Outside research I am an artist and creator, trained in piano, violin, erhu, bamboo flute, Peking opera, jazz vocals, and dance. I write poetry and theatrical reviews.
Learning Open-World Visual–Tactile Grasp Stability Prediction with Synthetic Data
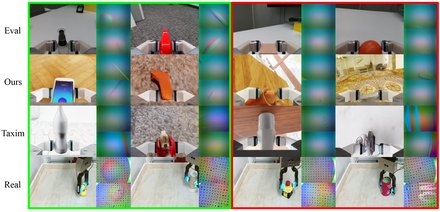
Grasp stability from vision and touch, trained on FEM-simulated data that beats both real data and rigid-body simulation on unseen objects.
FetchBench: A Simulation Benchmark for Robot Fetching
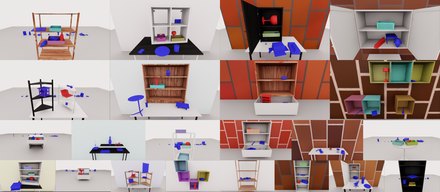
A benchmark for robot fetching in procedural scenes where grasping and motion planning are both required. Baselines from sense-plan-act pipelines to end-to-end policies top out at 20 percent success.